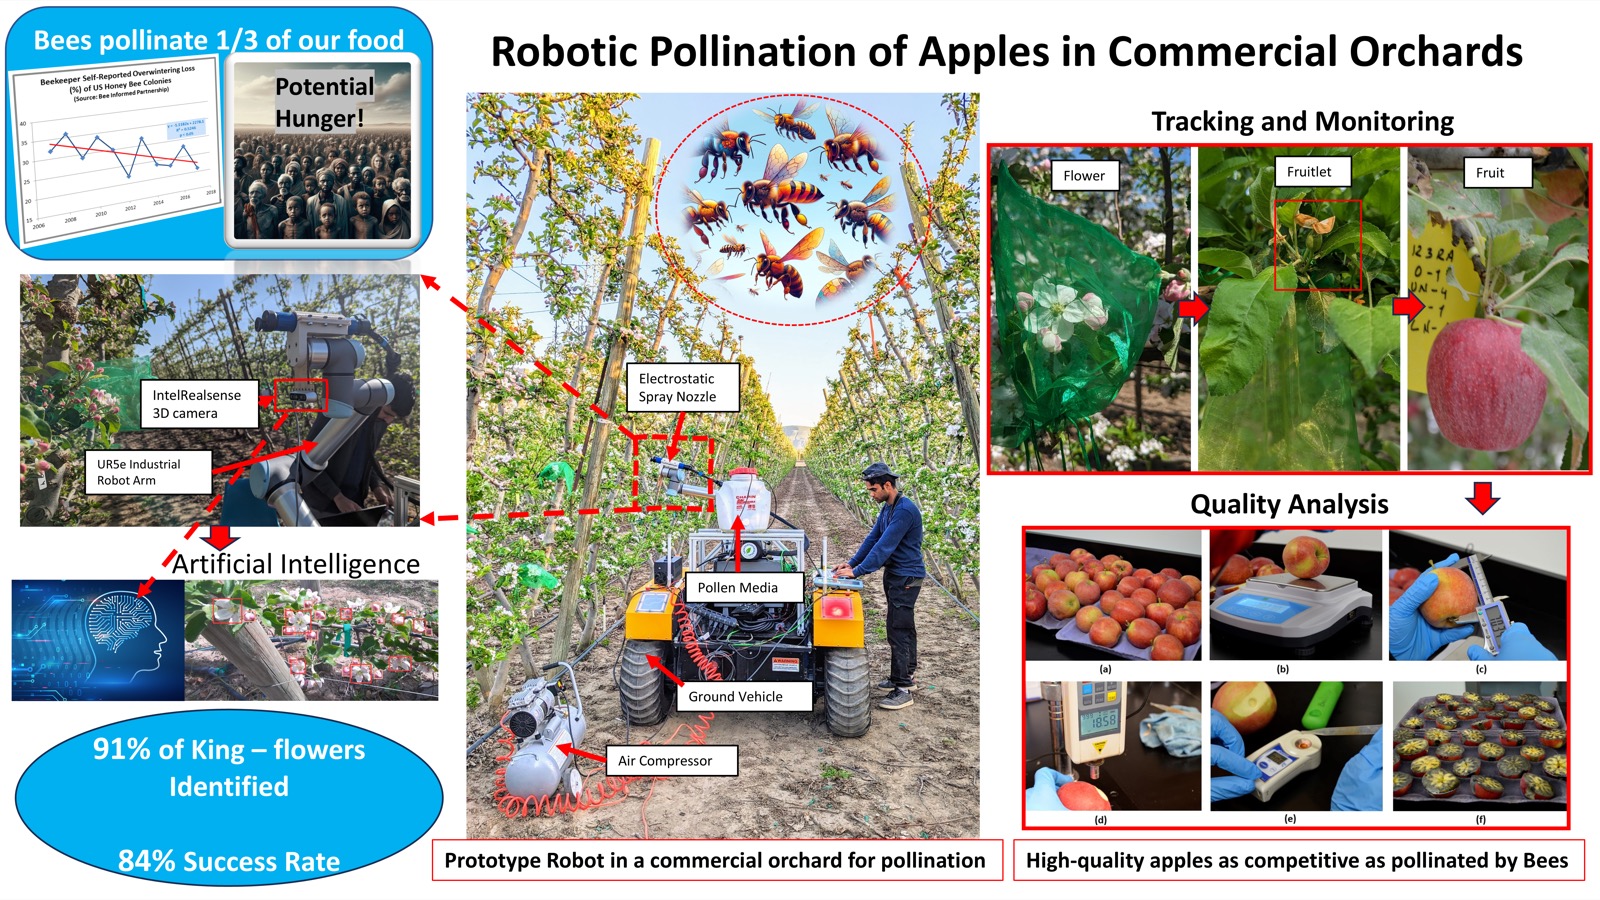
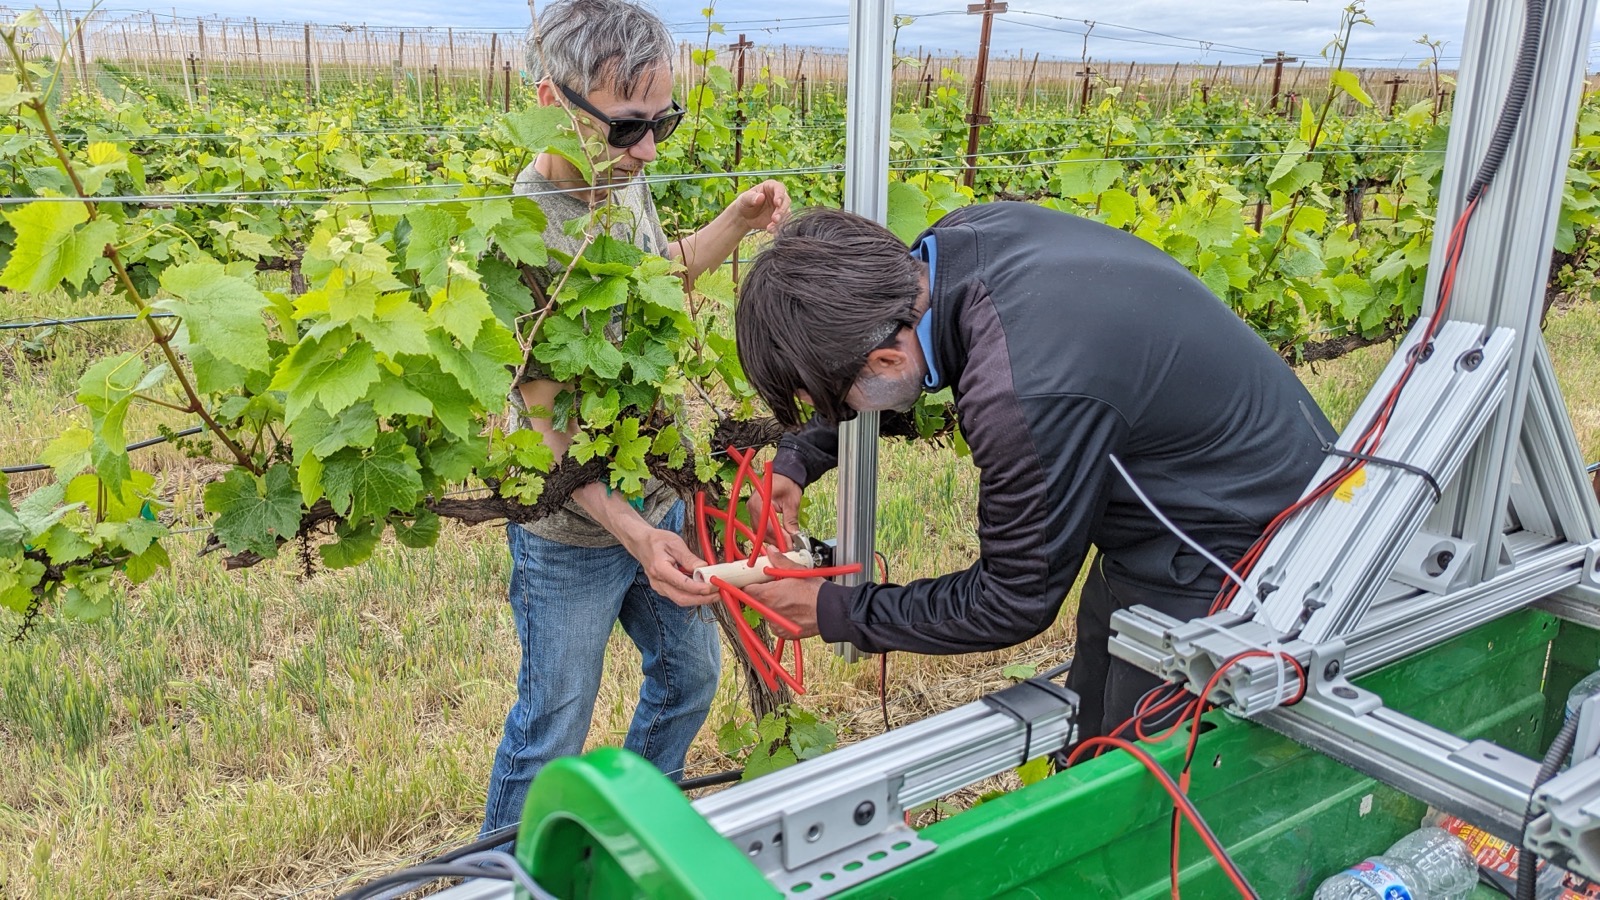
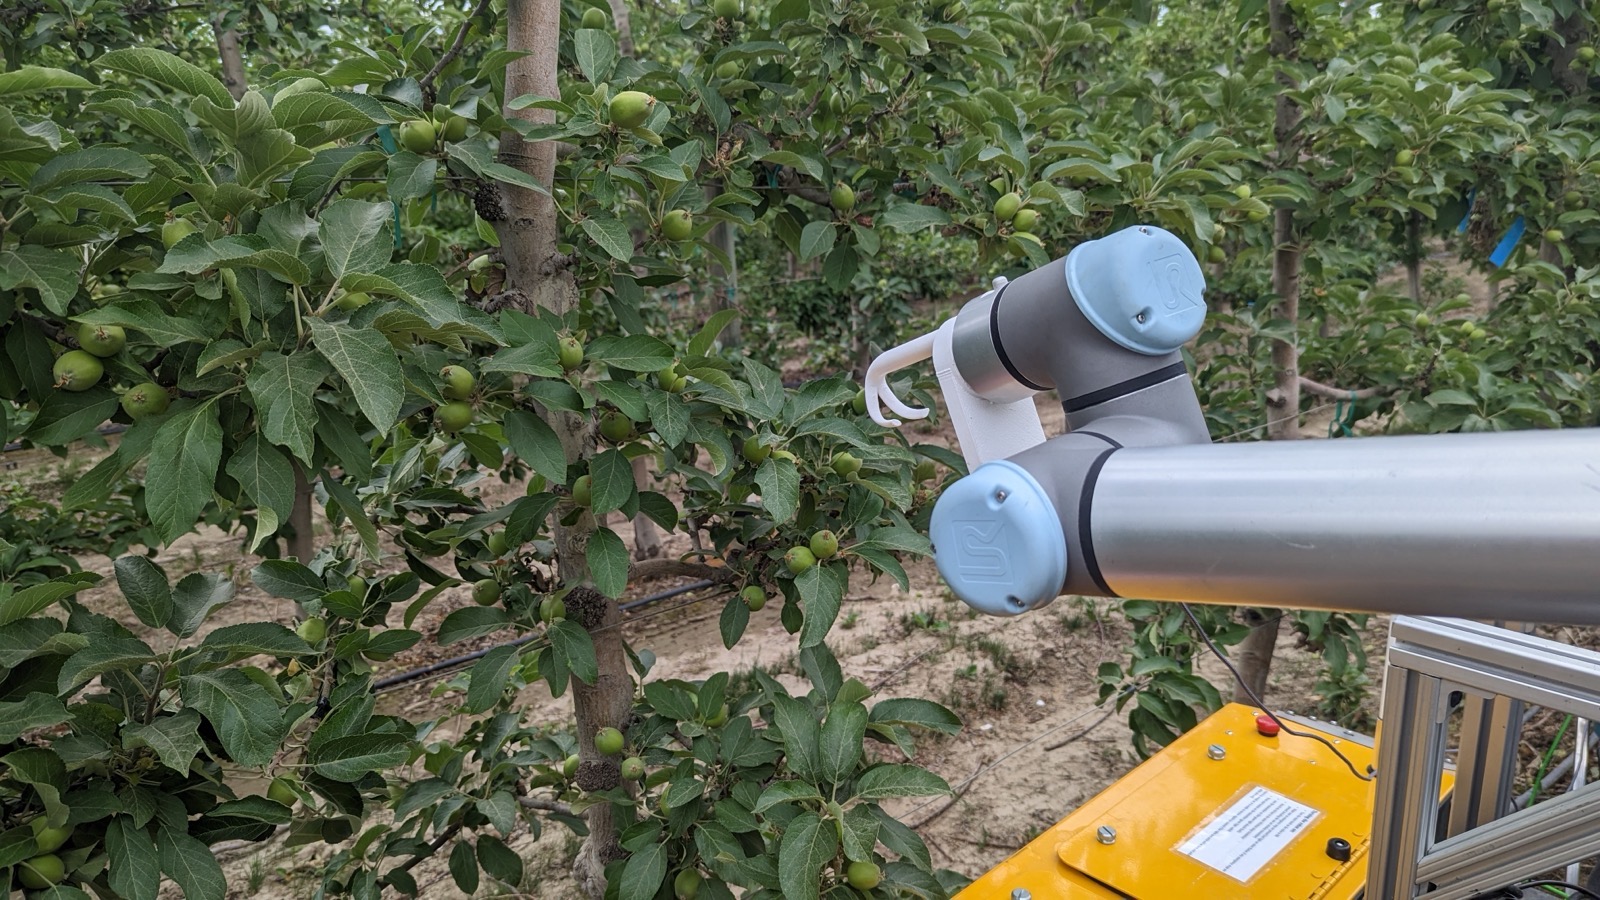
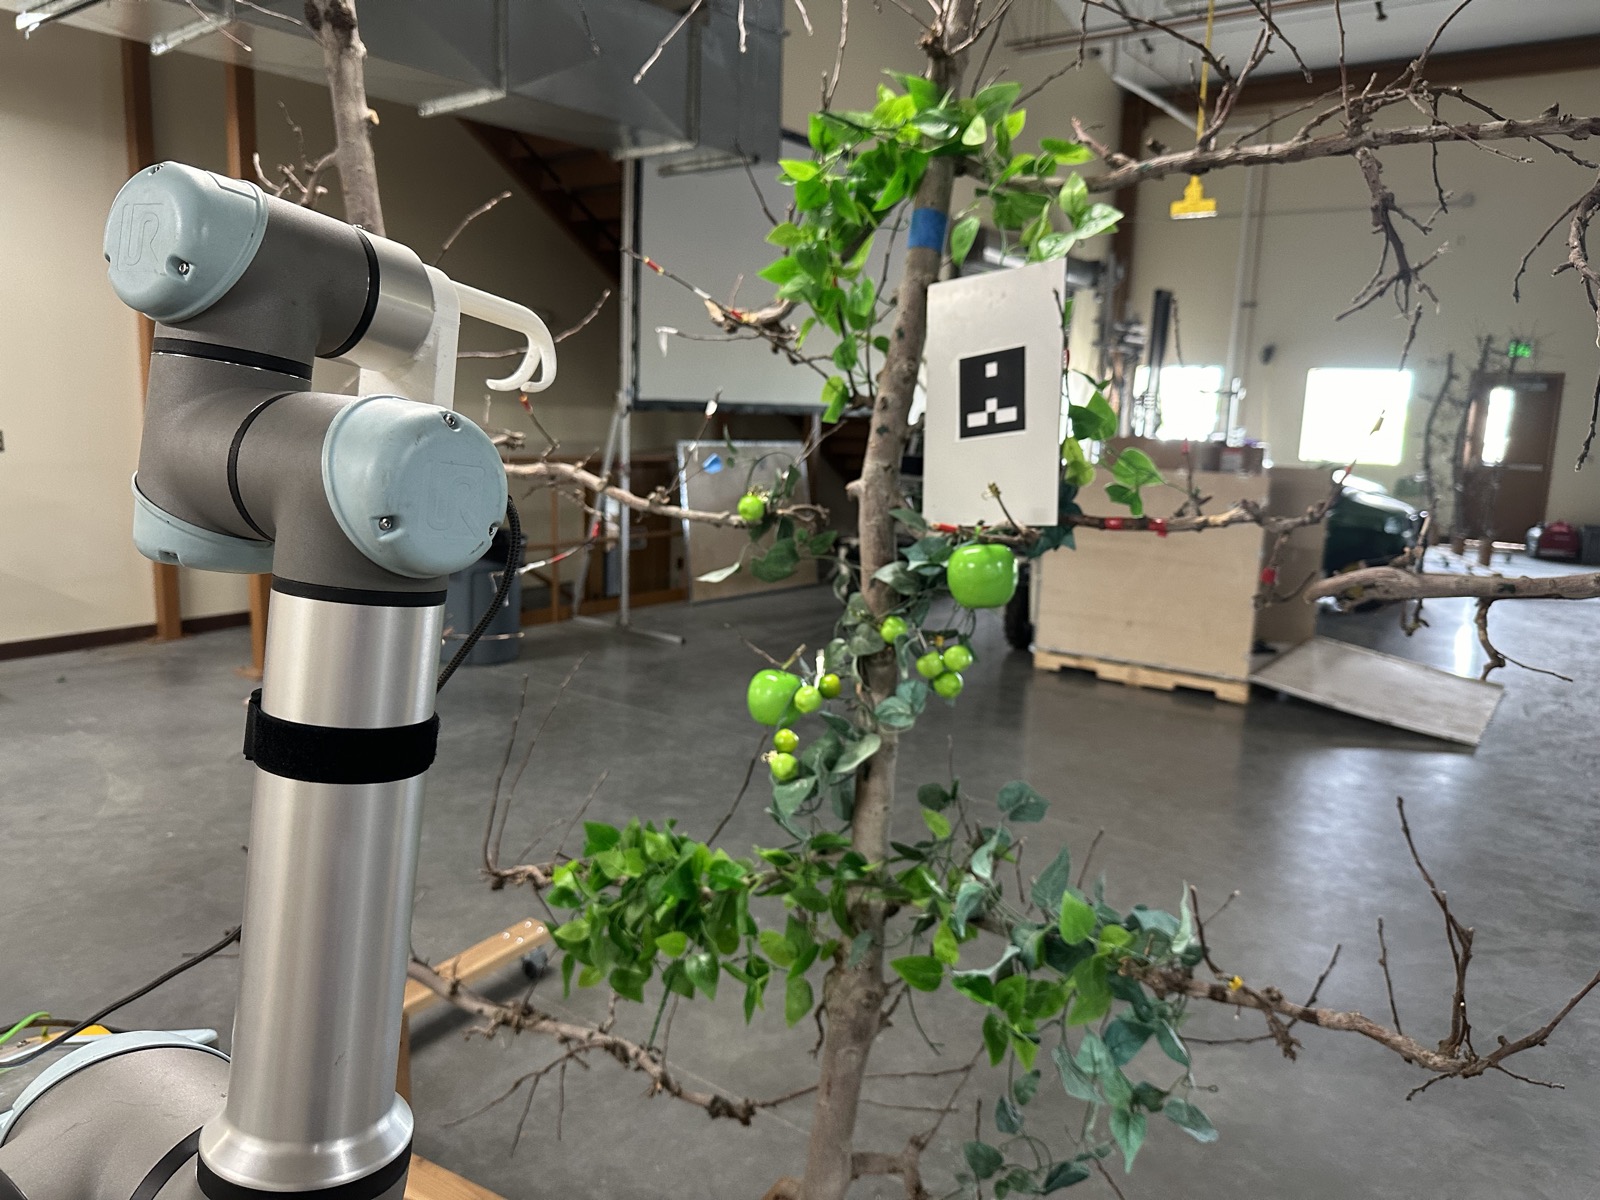
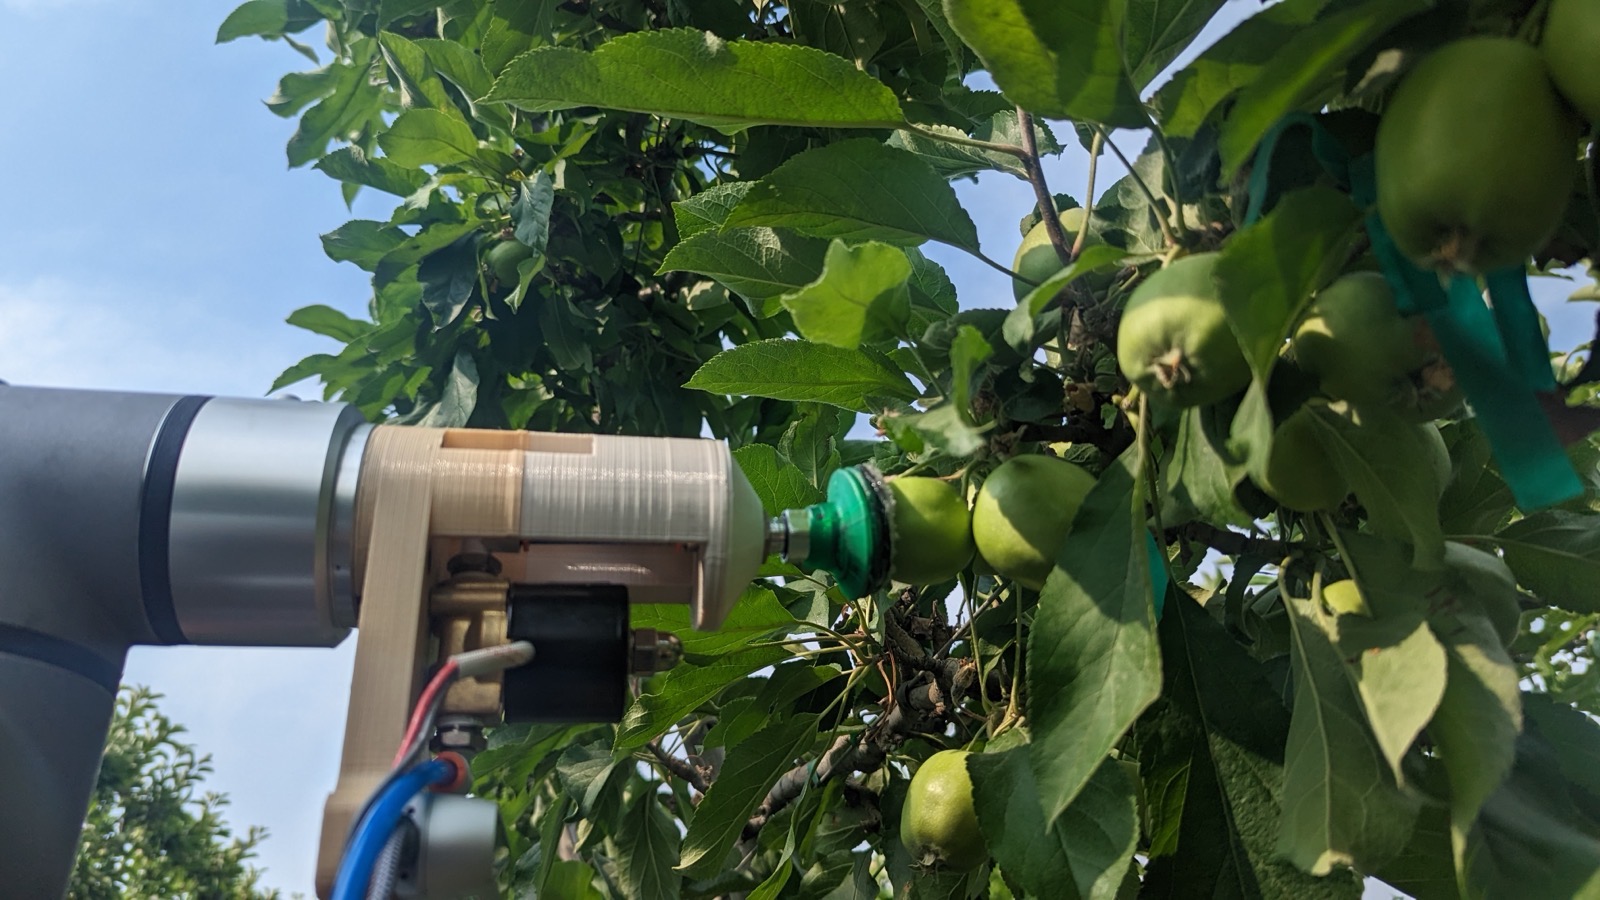
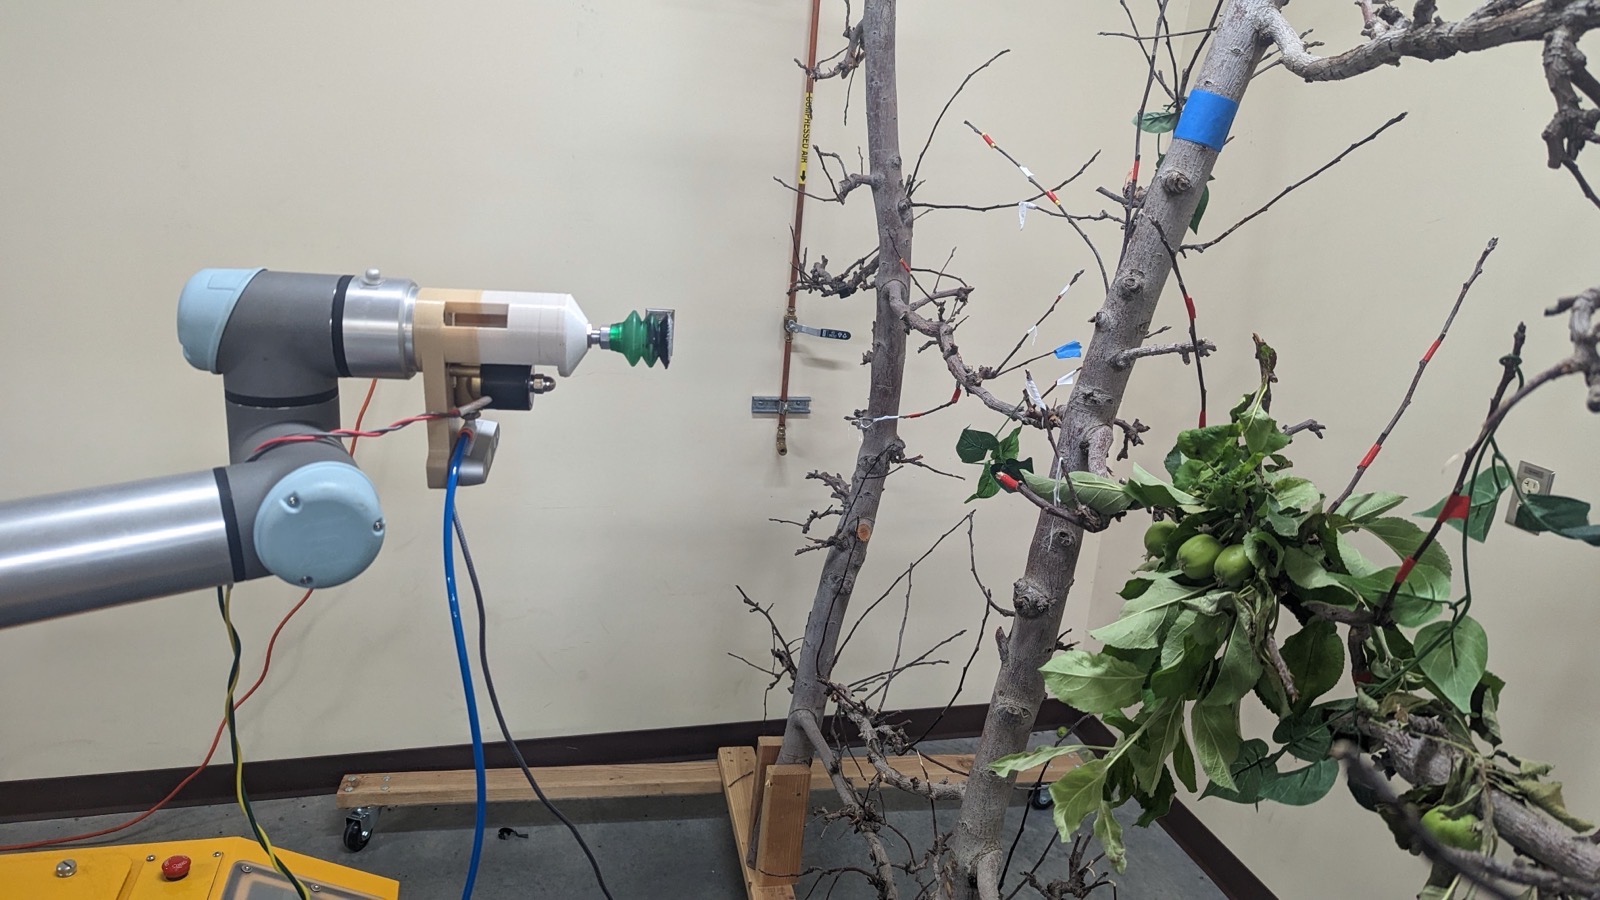
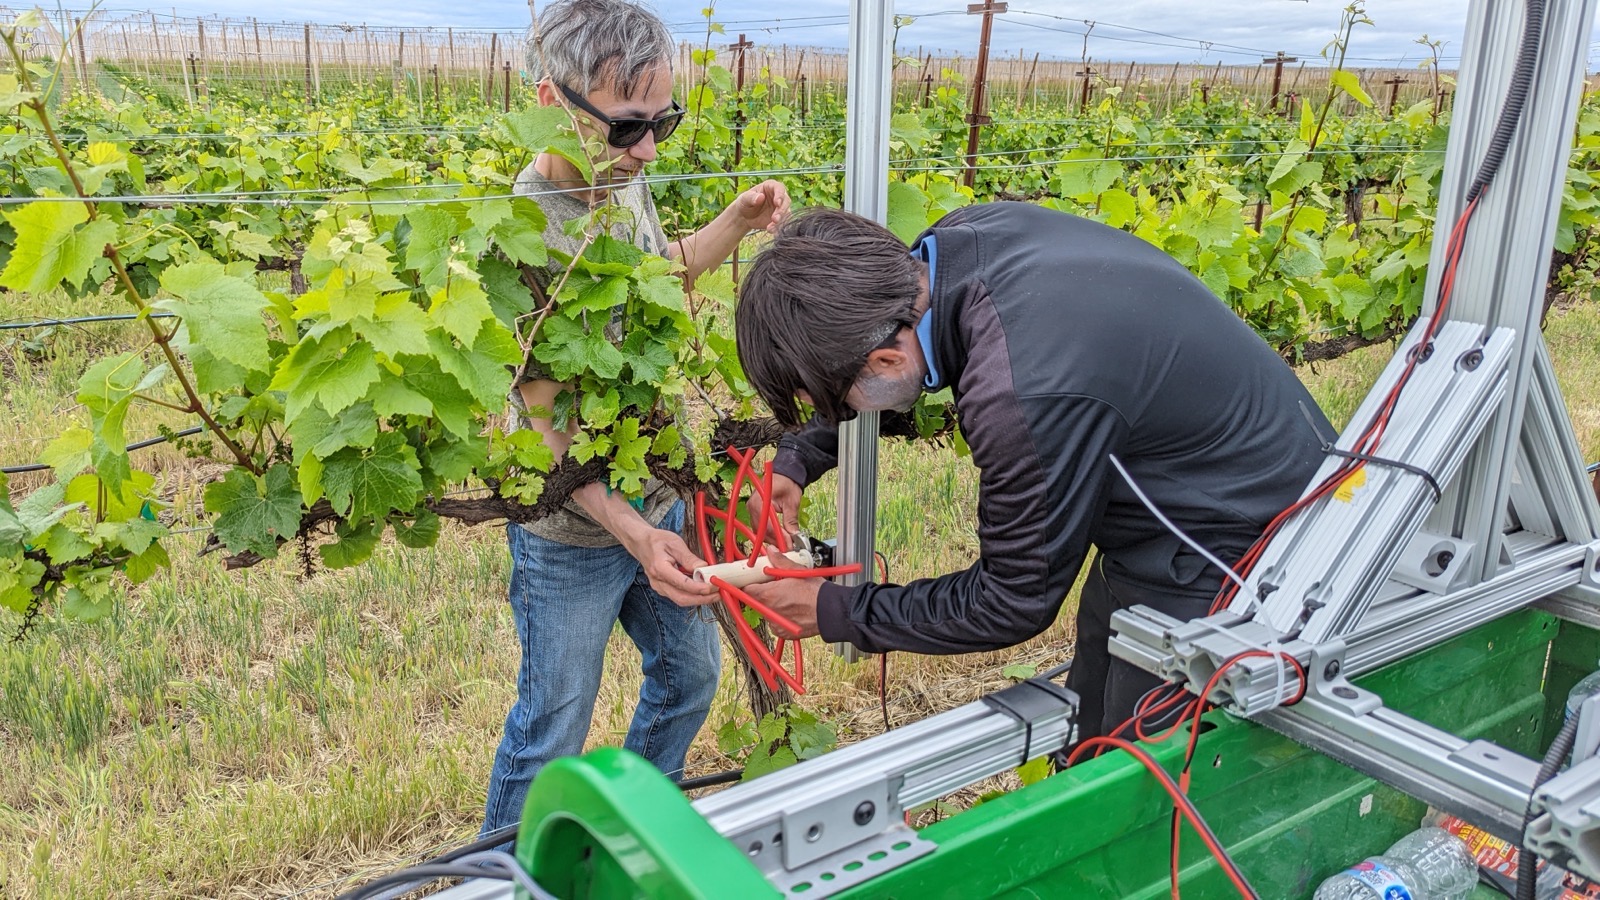
King-flower pollination system in a commercial apple orchardGrape shoot thinning robot in developmentBird-claw-inspired robot for fruitlet thinning in orchardsIndoor testing of bird-claw-inspired thinning robotSuction-cup end effector in action for fruitlet thinningIndoor evaluation of suction-cup-based end effectorRobotic setup for suction-cup-based fruitlet thinning
Perception & Sensing
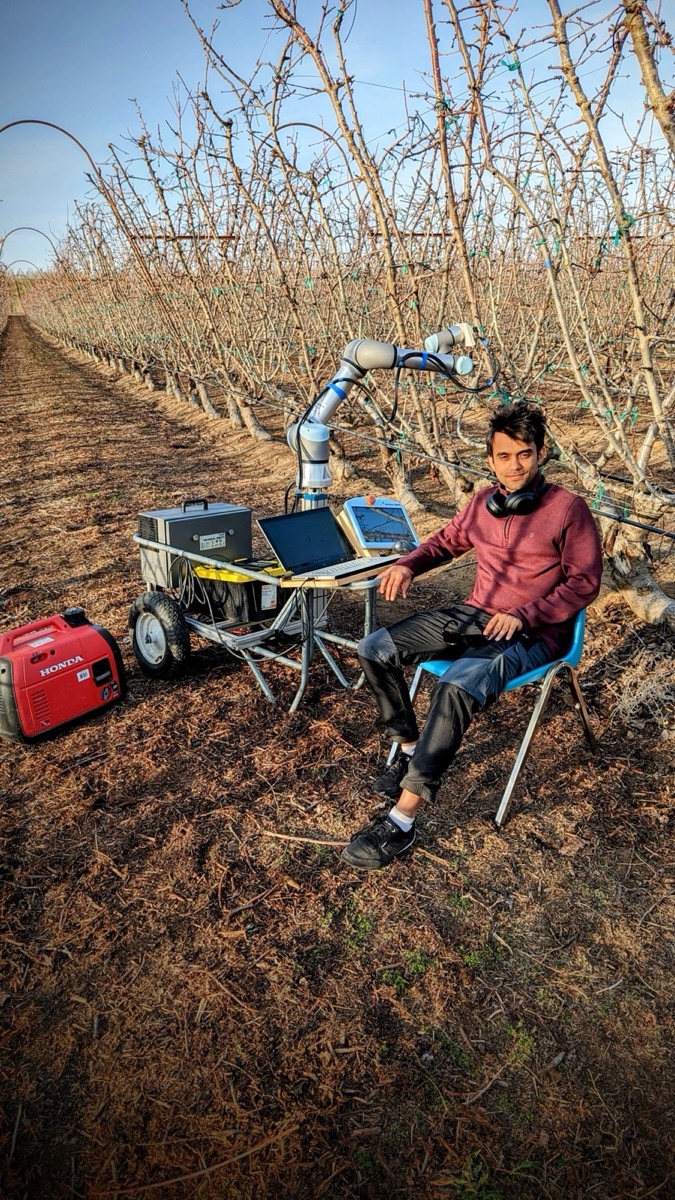
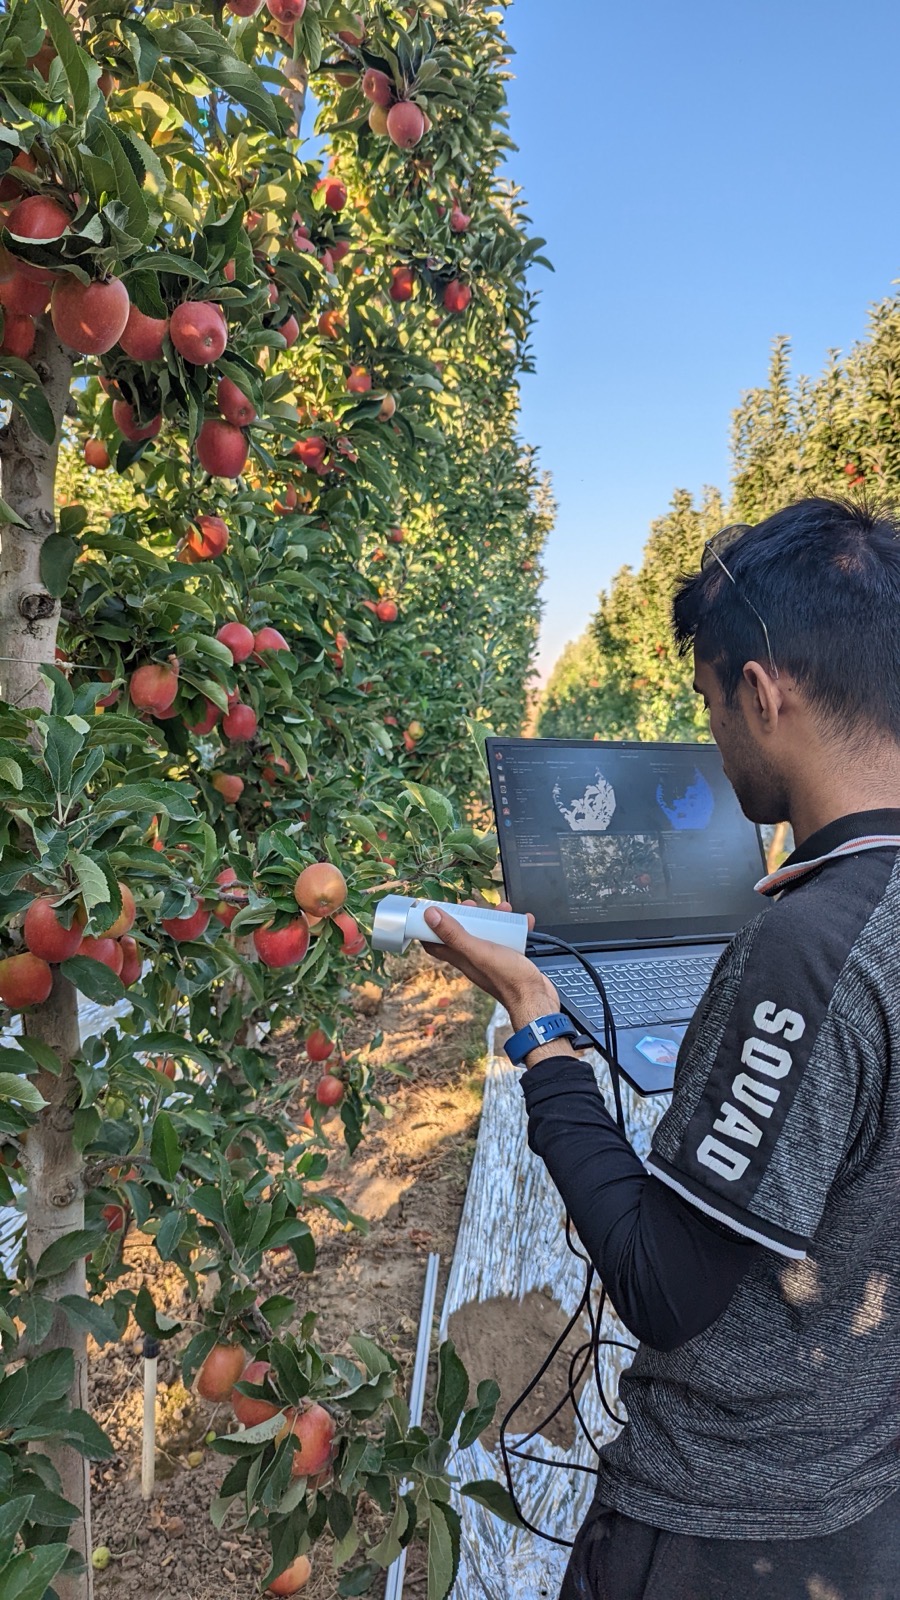
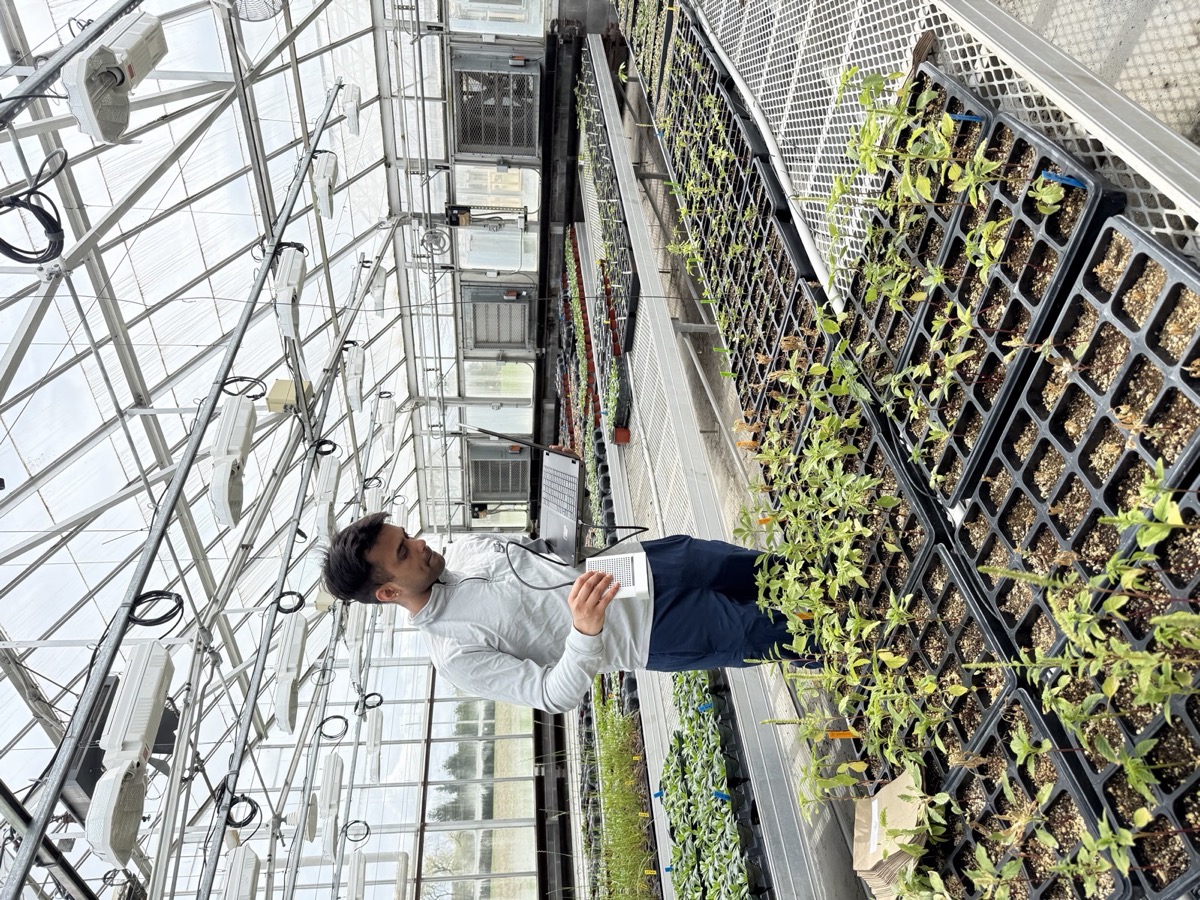
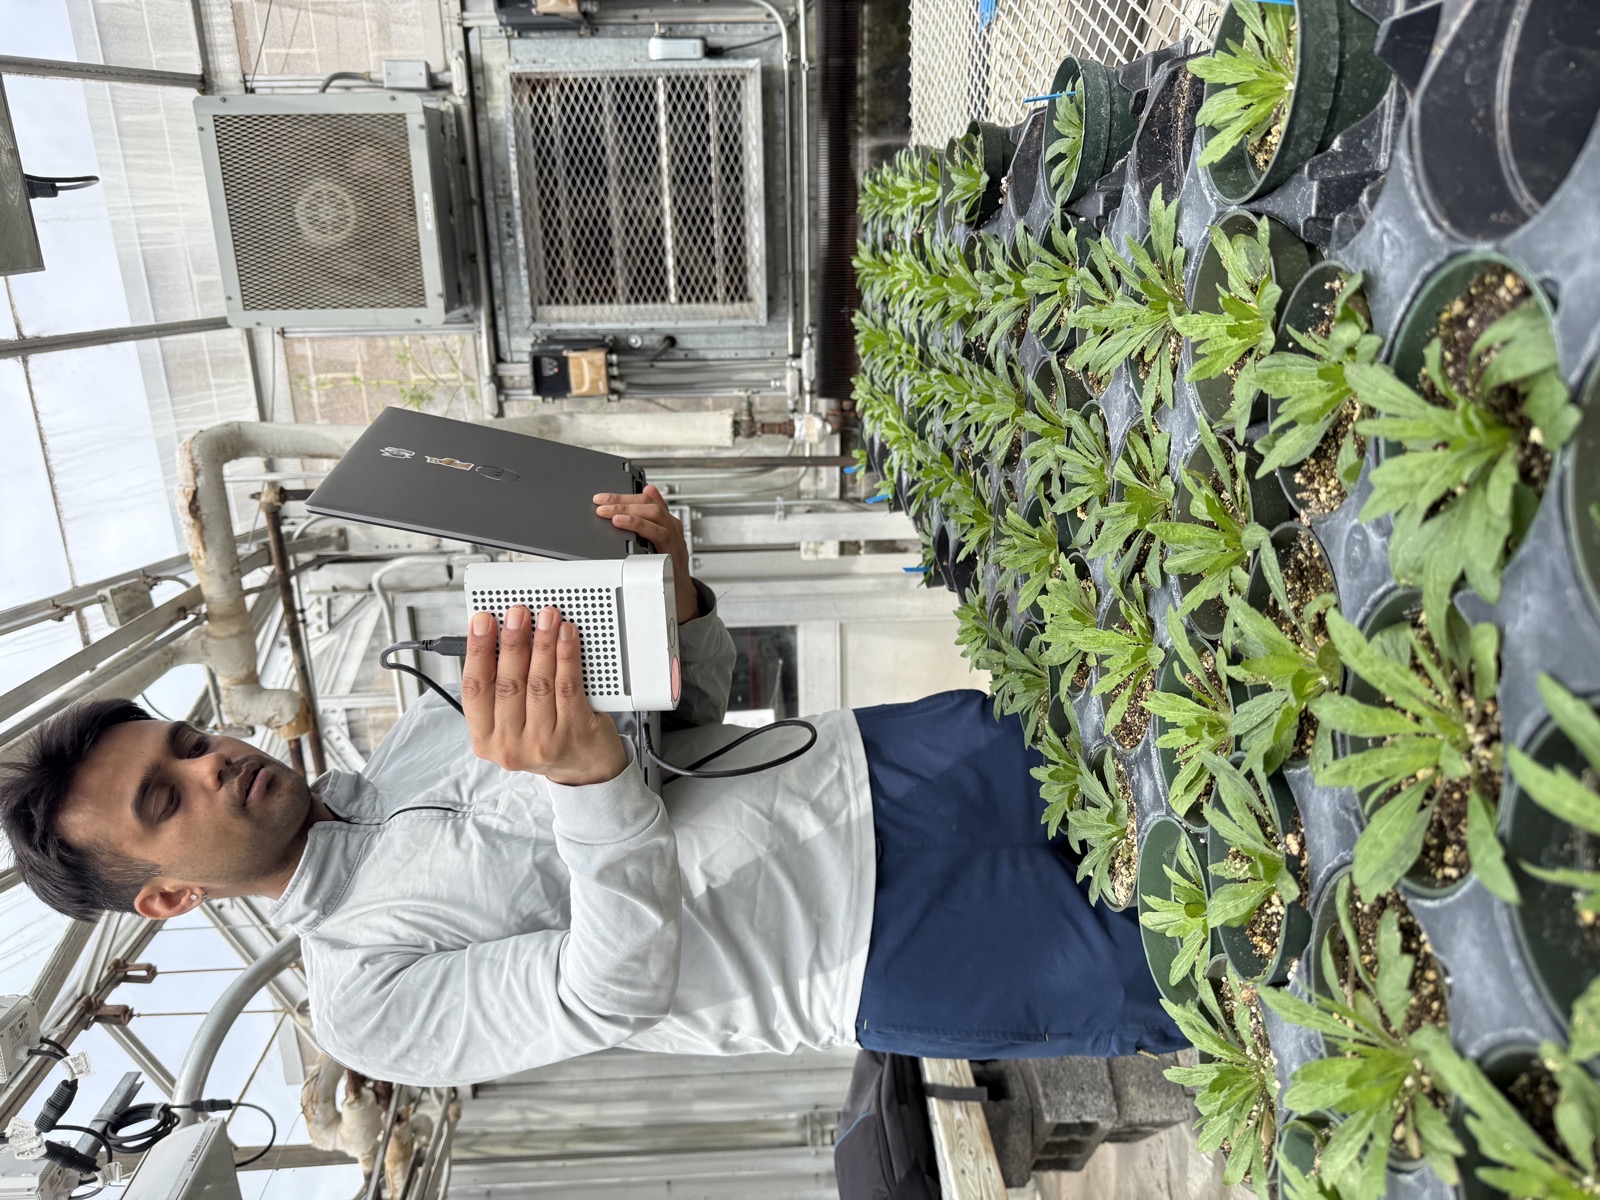
Scanning orchards with multiple vision systemsEarly orchard scanning and vision system developmentCherry orchard scanning with robotic setupScanning orchards during harvest seasonRGB-D and LiDAR fusion for depth improvementGreenhouse plant imagingGreenhouse plant imaging and phenotyping
Field Deployment
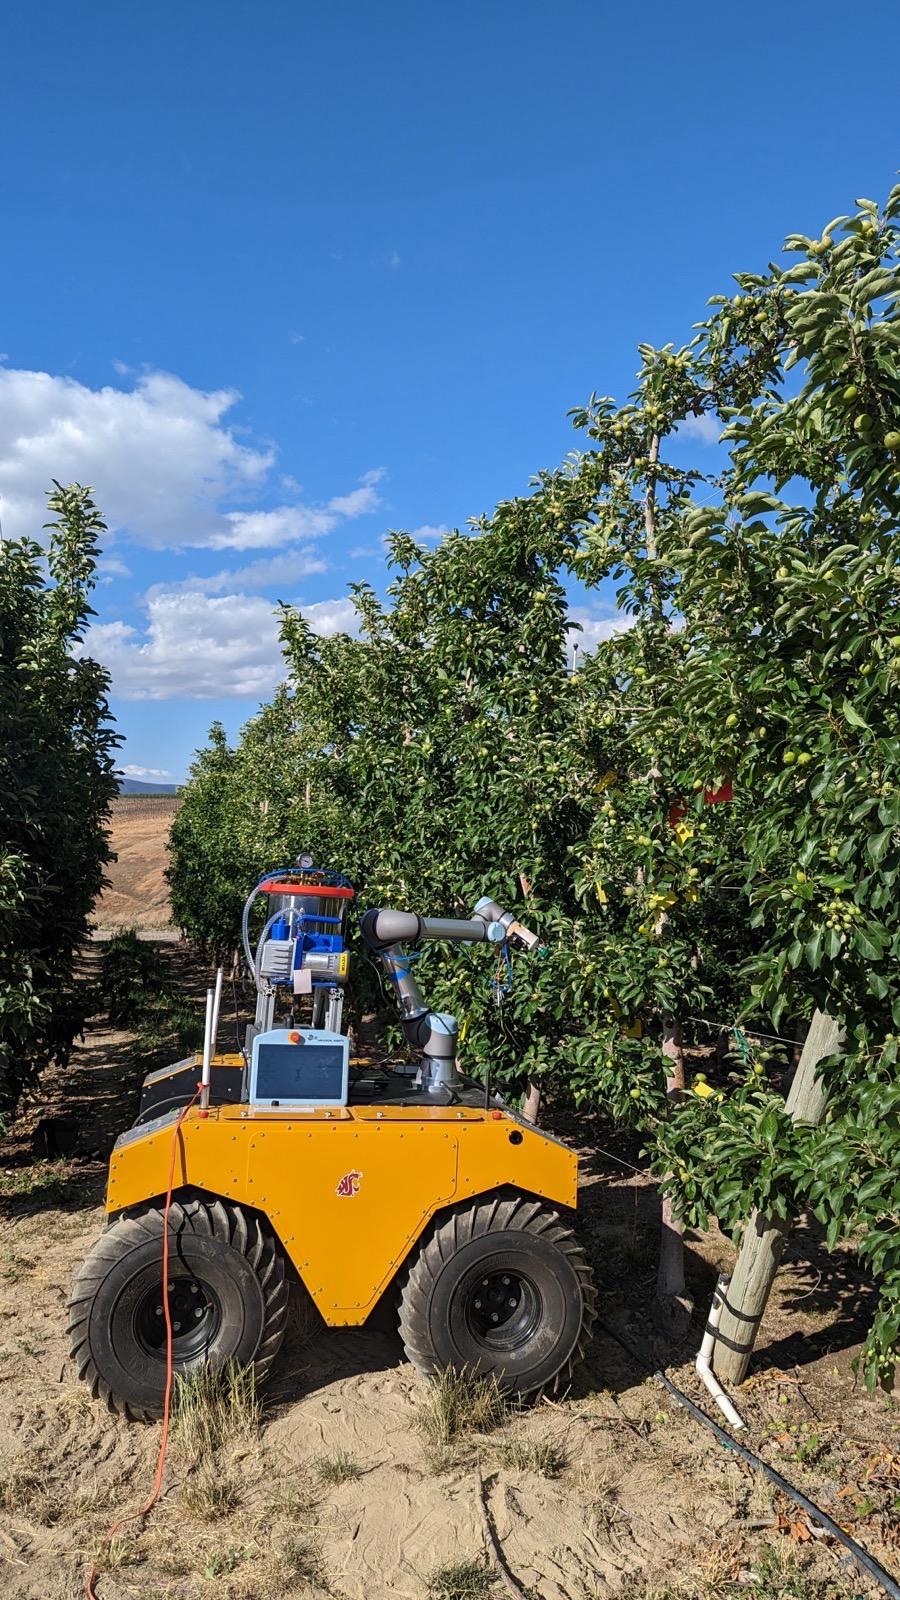
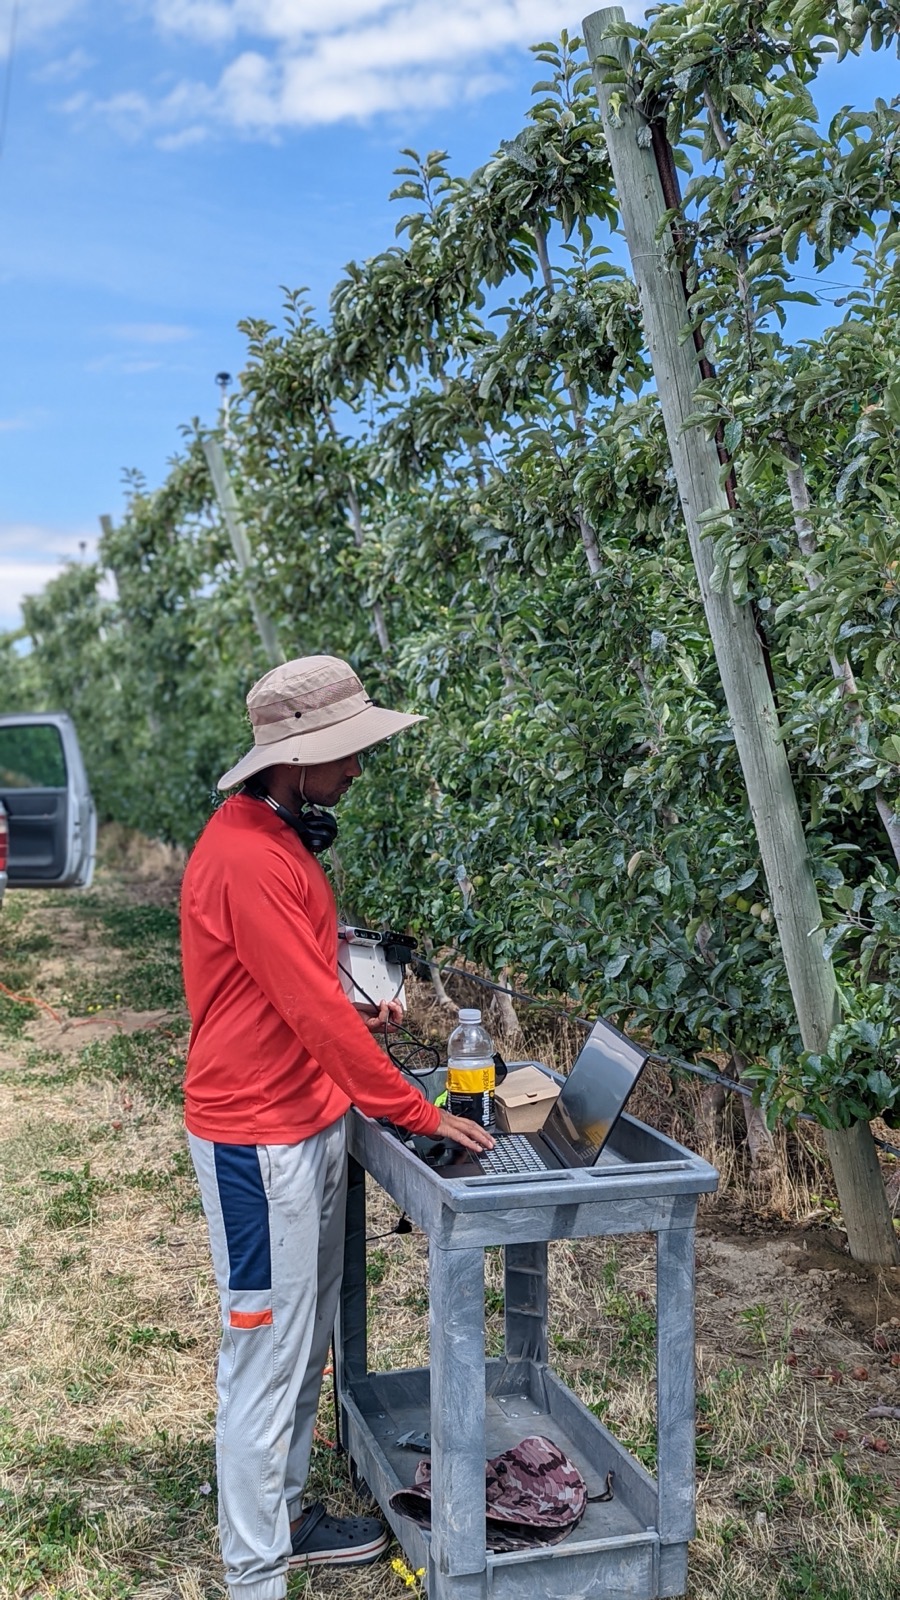
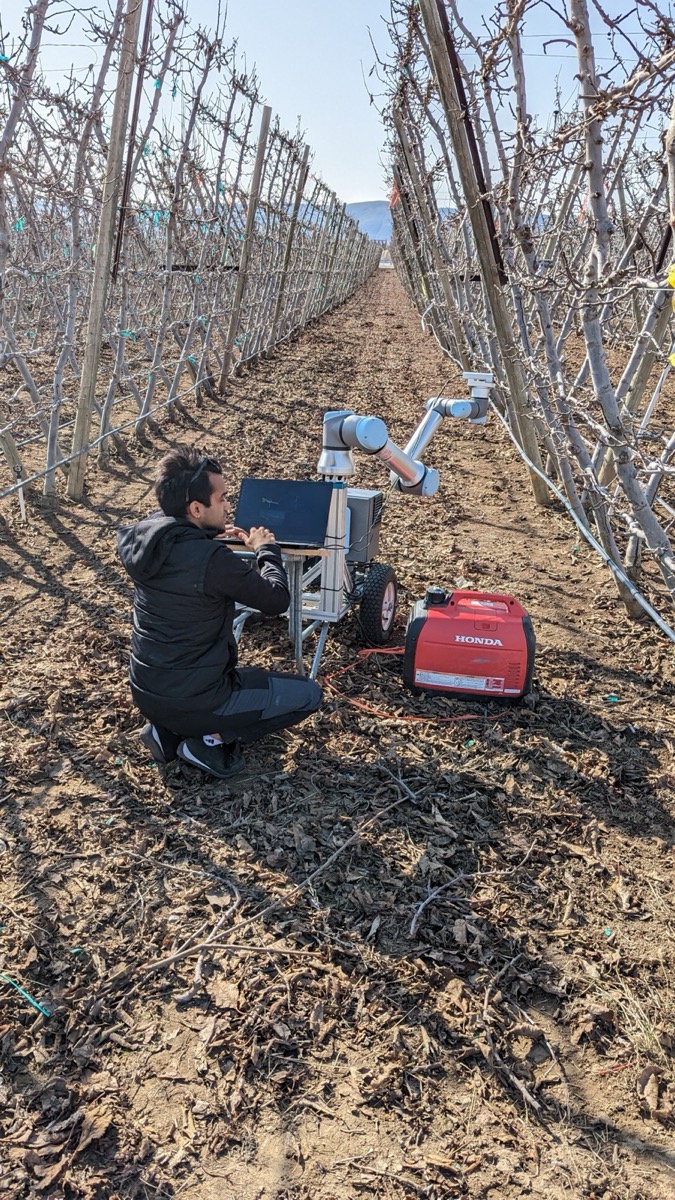
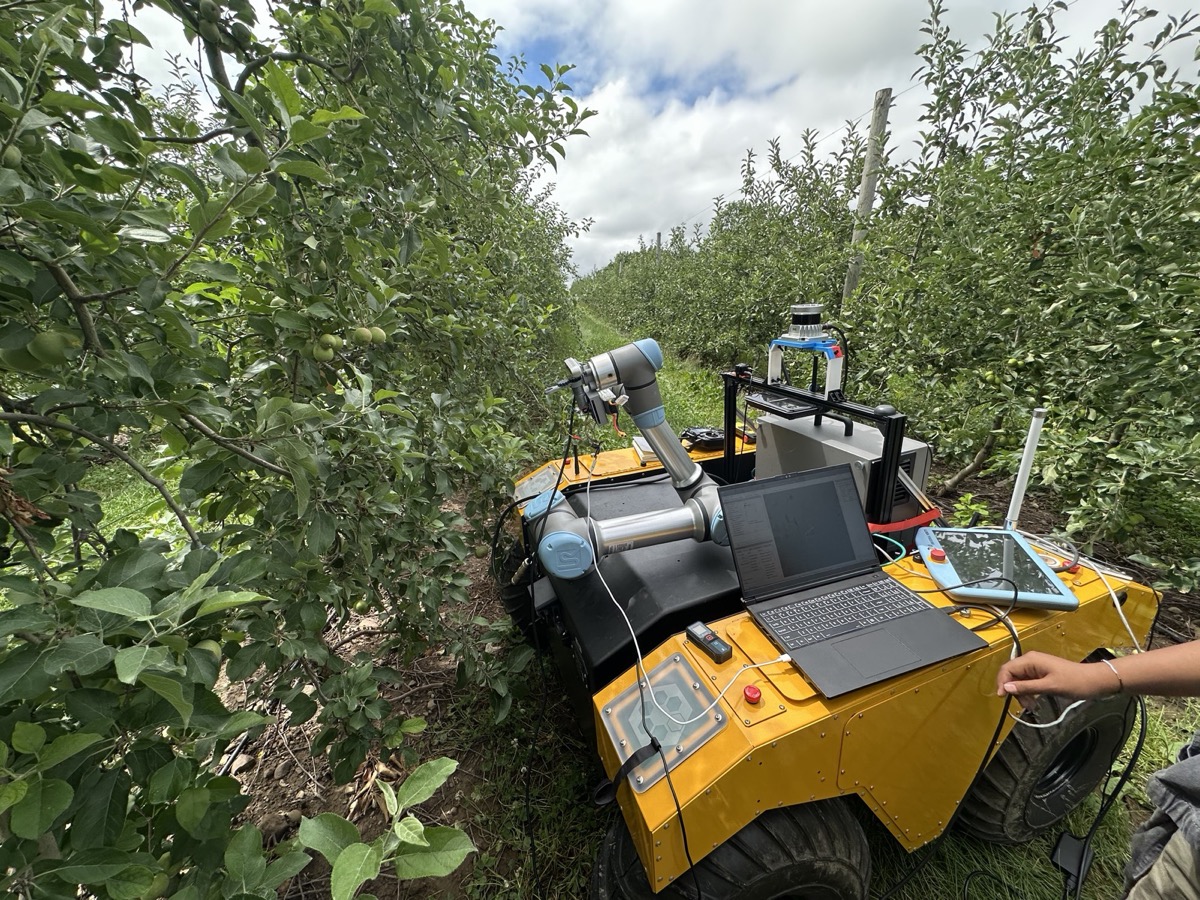
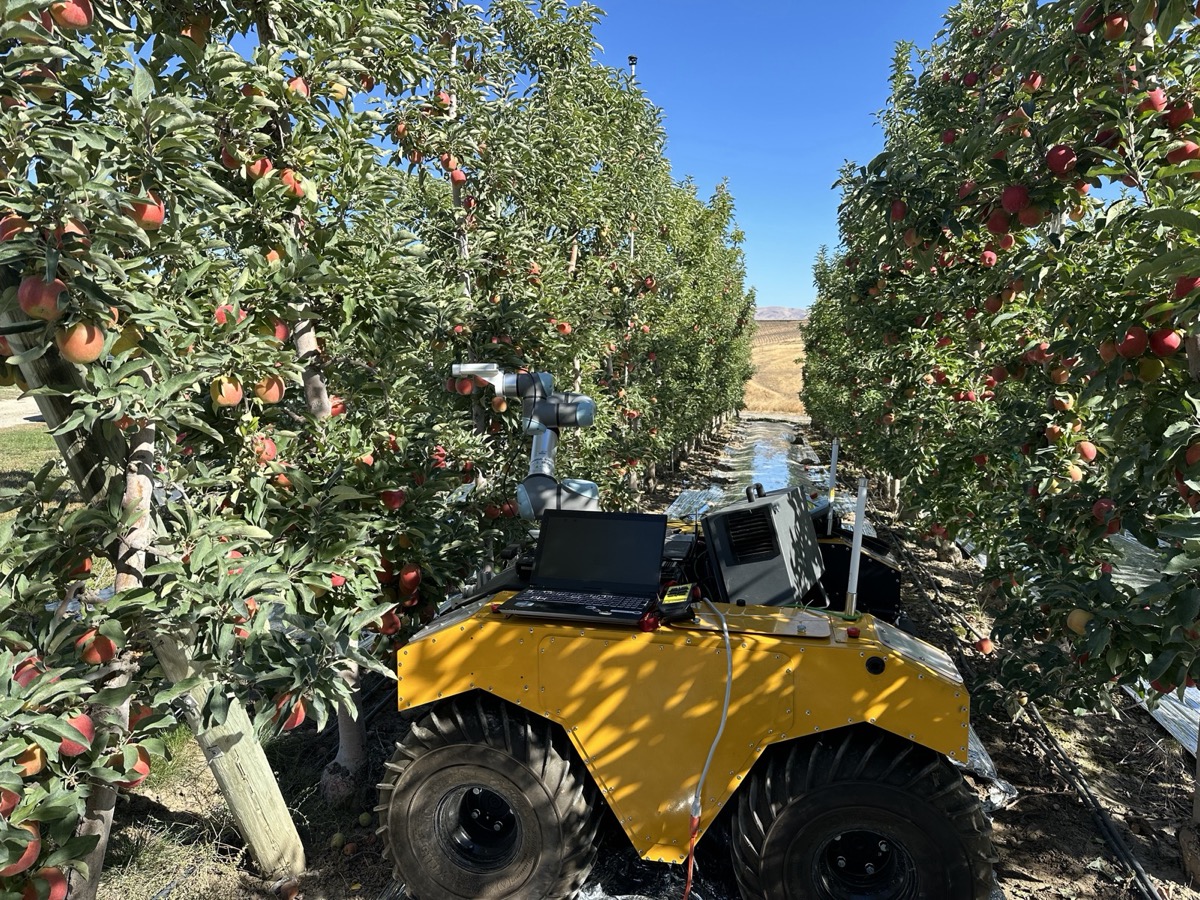
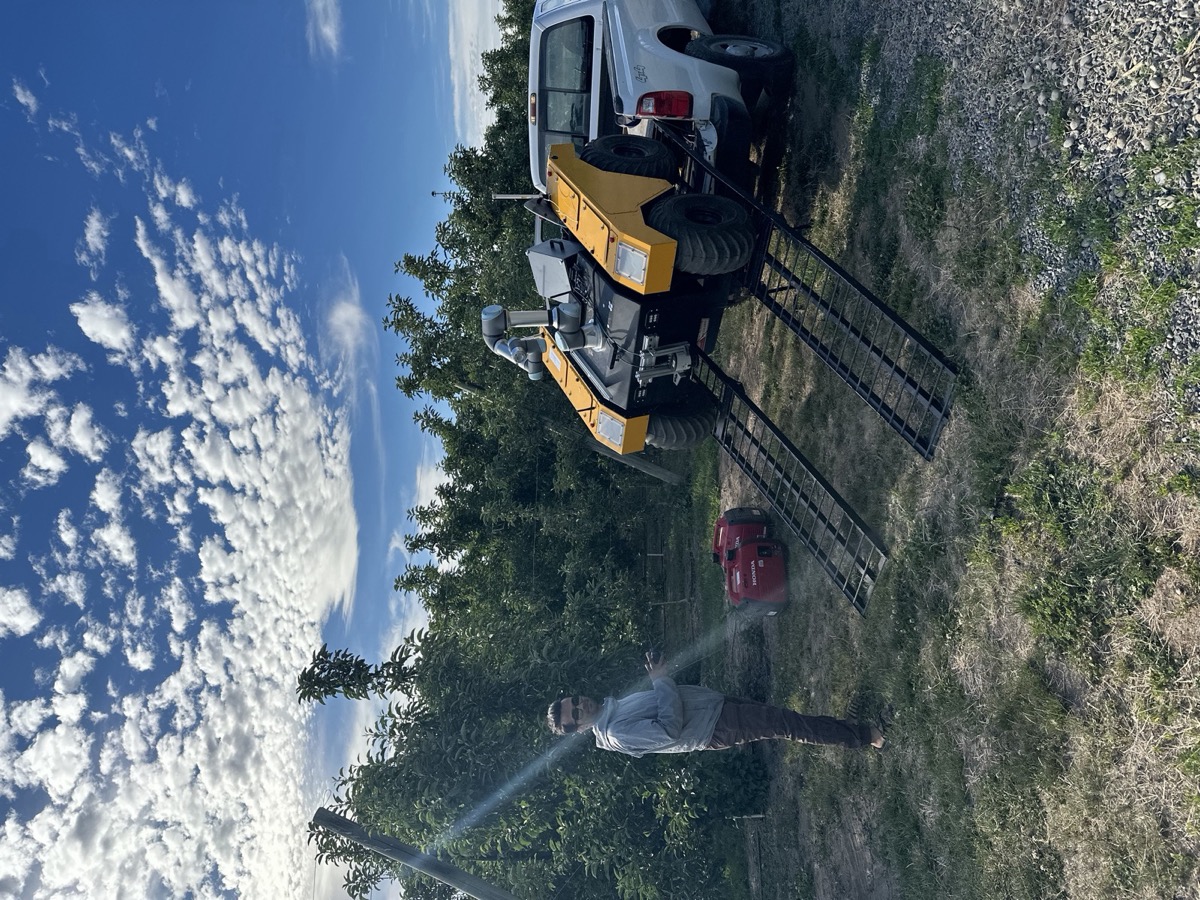
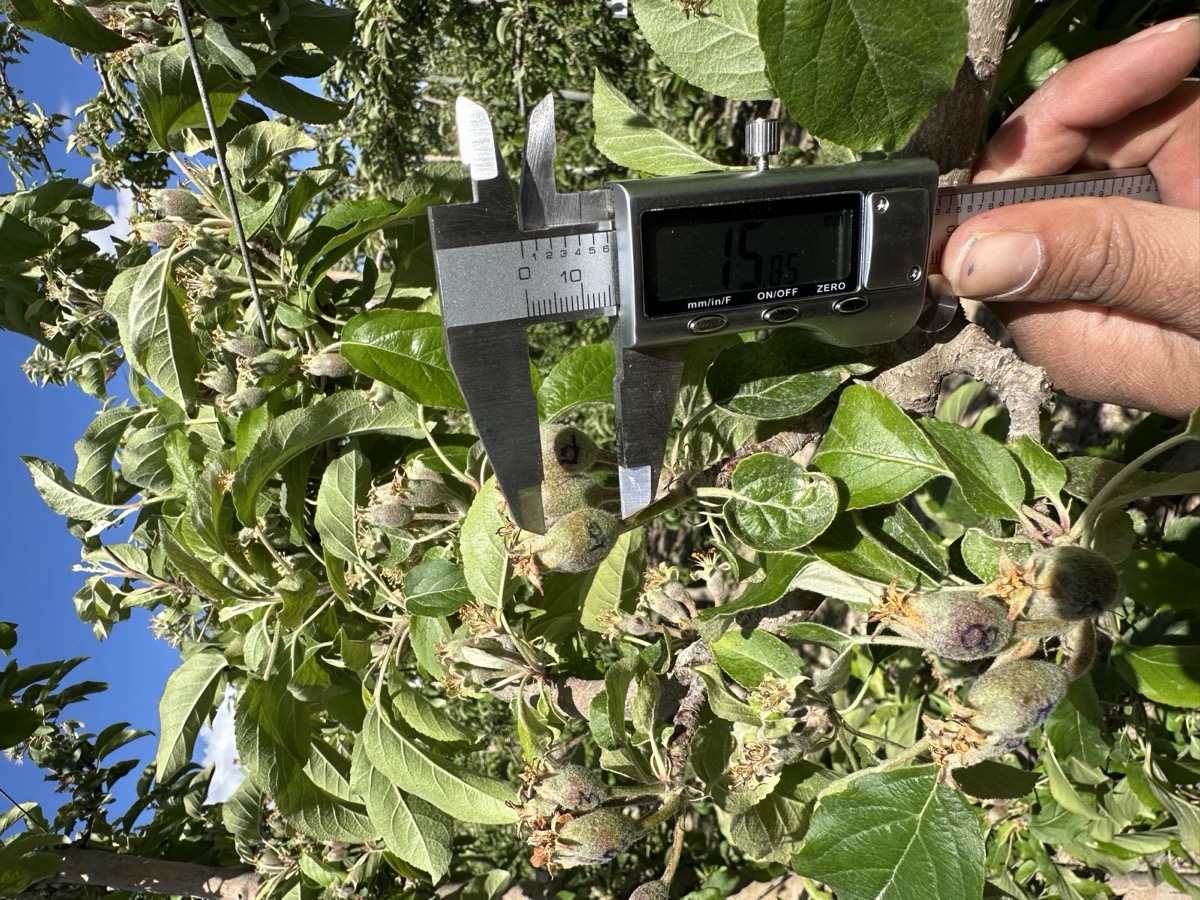
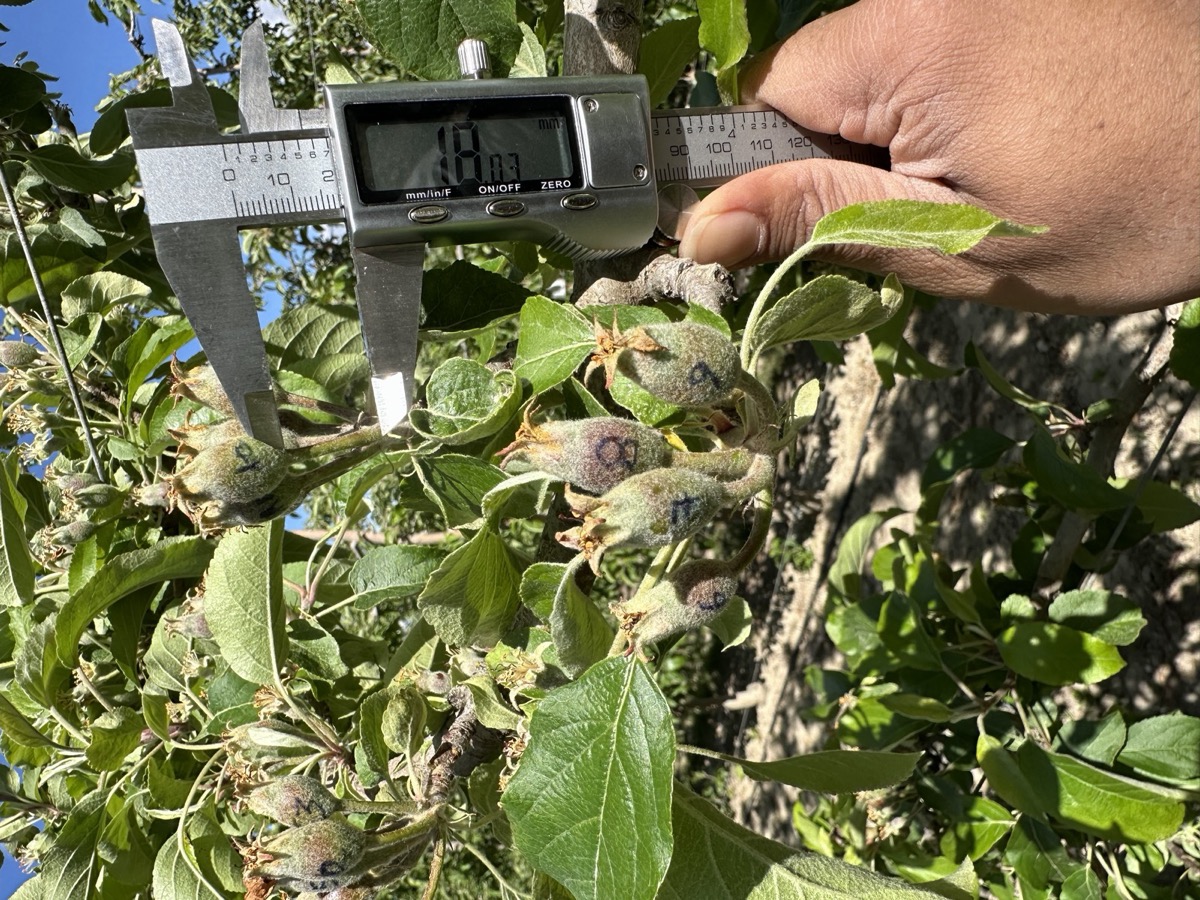
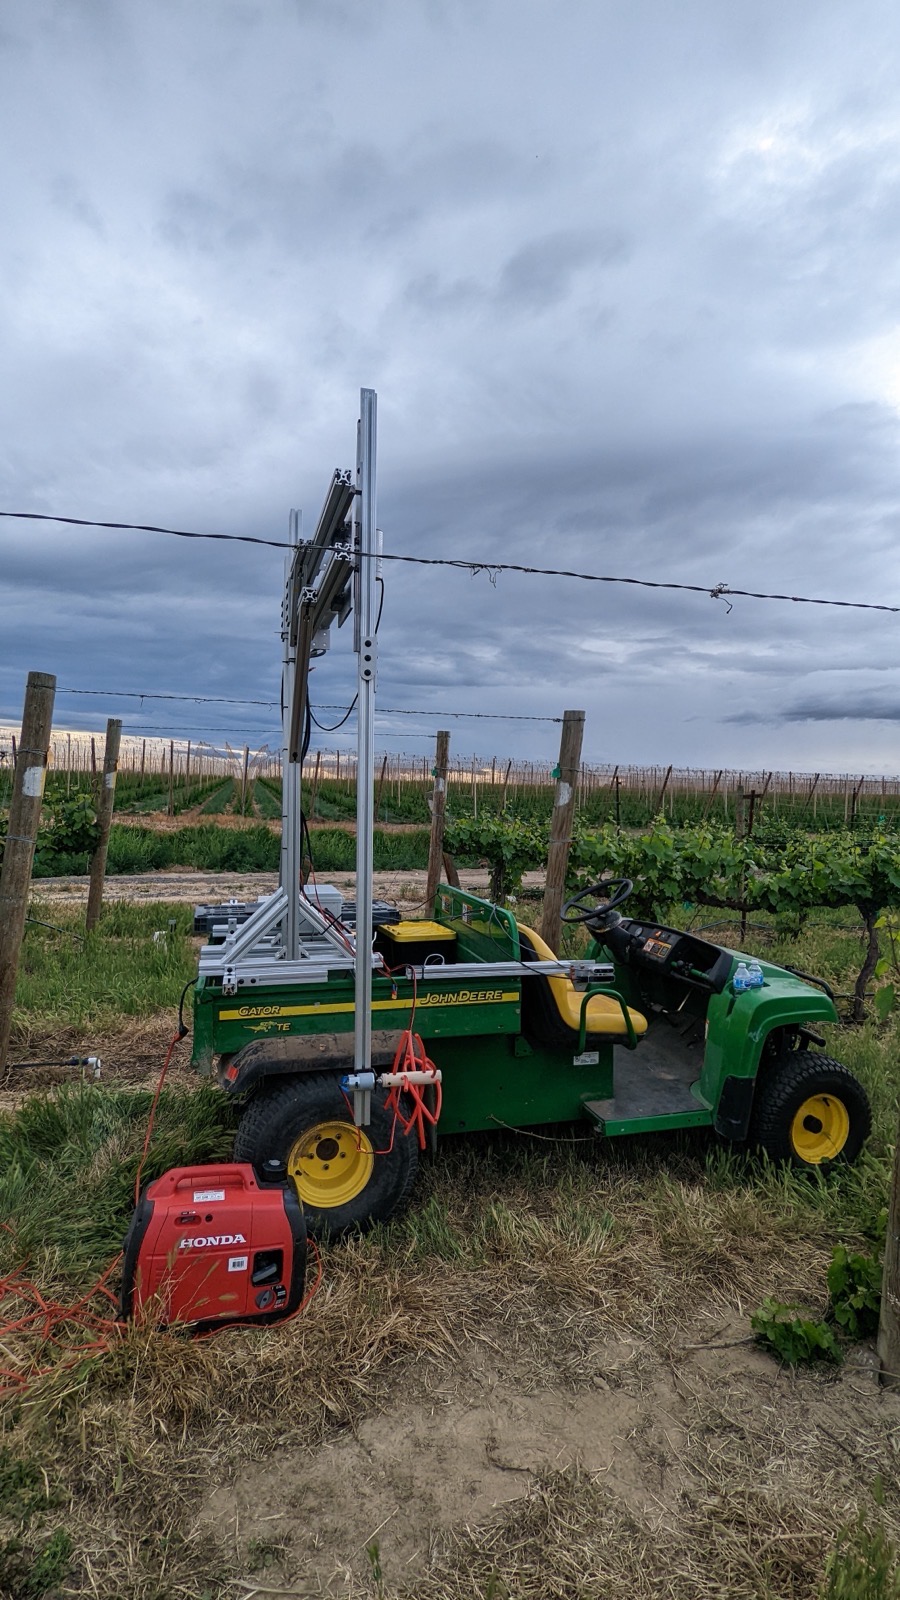
Harvest season — robot deployed in the fieldLoading robot onto a truck for orchard deploymentMeasuring ground-truth data for early-stage fruitletsGround-truth measurement in the fieldField work and data collectionOutdoor field experiments